First New Zumo Board out of the Reflow Oven

Andreas populated the first board with SMD parts and sent it through the reflow oven. The 32 kHz quartz is missing because not all parts arrived on time. The soldering of the Freescale Kinetis K22 microcontroller is not perfect yet, so will need some tweaking and inspection under the microscope, as well some other parts. Christian will do an inspection and electrical tests, then it will be my job to get it connected to the debugger. Keep my fingers crossed to get a blinking LED šŸ™‚

New Zumo Bot Board, mostly populated

First new Zumo Robot Board, out of the Reflow Oven
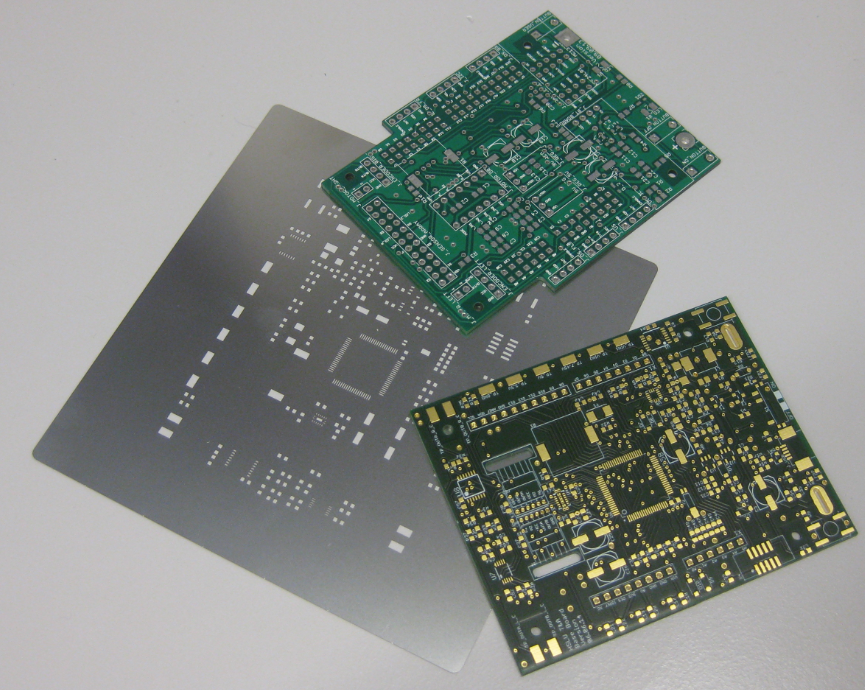
New Zumo Robot PCBs Arrived!

As you might have read it already: for the new semester we plan the next generation of Sumo Robots: still based on the Pololu Zumo Chassis, but instead using the FRDM board with the processor, we directly put a Kinetis K20 processor on the board :-).

Old (top) and new (bottom) PCB with solder mask

Old (top) and new (bottom) PCB with solder mask

Continue reading →

Slow 32 kHz Oscillator Startup

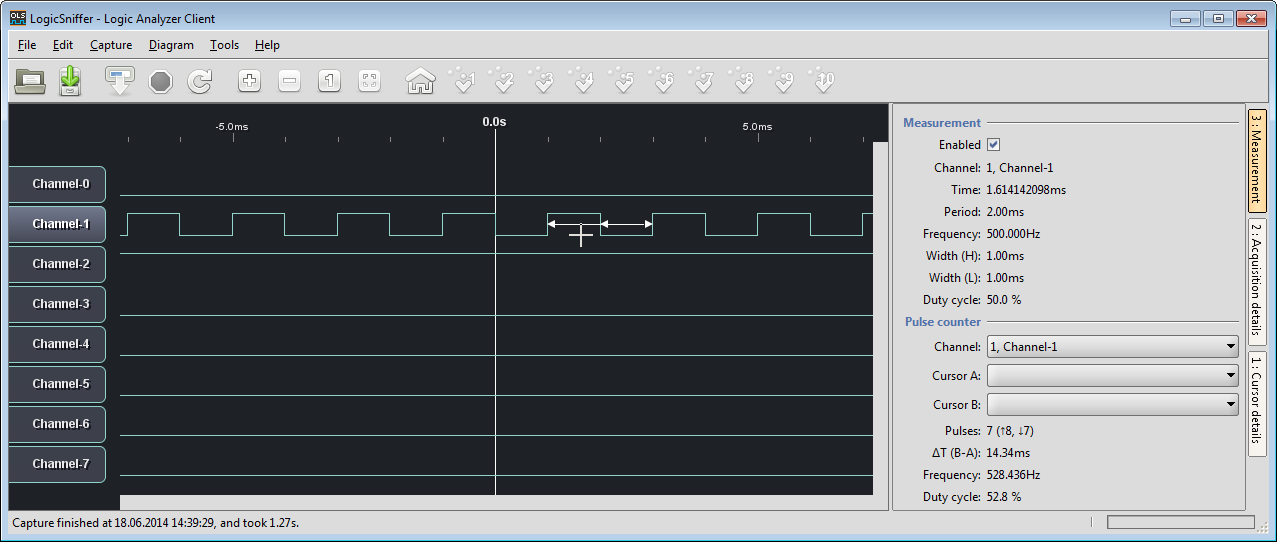
In an IoT (Internet of Things, see “IoT: FreeRTOS Down to the Micro Amps“) project I’m using the Freescale KL15Z microcontroller. The nodes are moving around, and the board is using a special inductive charging ‘on the fly’ when nearby the charging station. The energy is stored in capacitors, so no batteries are needed. That worked very well, but some system failed: they need to quickly check sensor signals after power-up. Tracking down the problem, it was obvious that most of the systems failed because it took them too long to boot from the power-on reset. So I instrumented the application to toggle an LED so I can monitor what happens: It was over 400 ms after power-on! Yikes!

413 ms for startup

413 ms for startup

Continue reading →

Tutorial: DIY Kinetis SDK Project with Eclipse – Board Configuration

In “Tutorial: DIY Kinetis SDK Project with Eclipse – Startup” I showed how to create a Kinetis SDK project from scratch. In this post it is about adding the board initialization files. With the board initialization the peripheral clocks and pin muxing is configured.

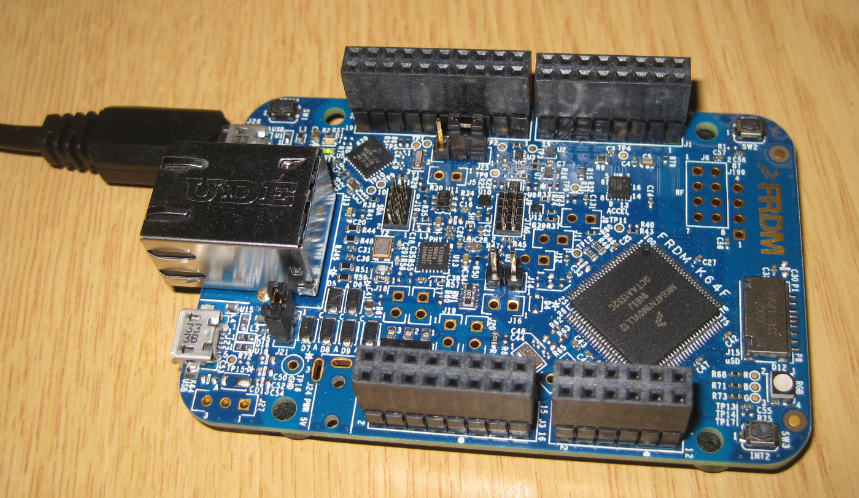
MK64FN1M0VLL12 on FRDM-K64F

MK64FN1M0VLL12 on FRDM-K64F

Continue reading →

Programmable Ultrasonic Sensor Shield for FRDM Board

“Note to myself: post articles about what students have done this semester…”

Students have turned in their semester project work. I have set for myself a goal to briefly describe to the ‘outside’ world what they did, as an inspirational source :-). So here is a first article about the project completed by Christoph Bühlmann who developed a shield for the FRDM-KL25Z board: a programmable ultrasonic shield:

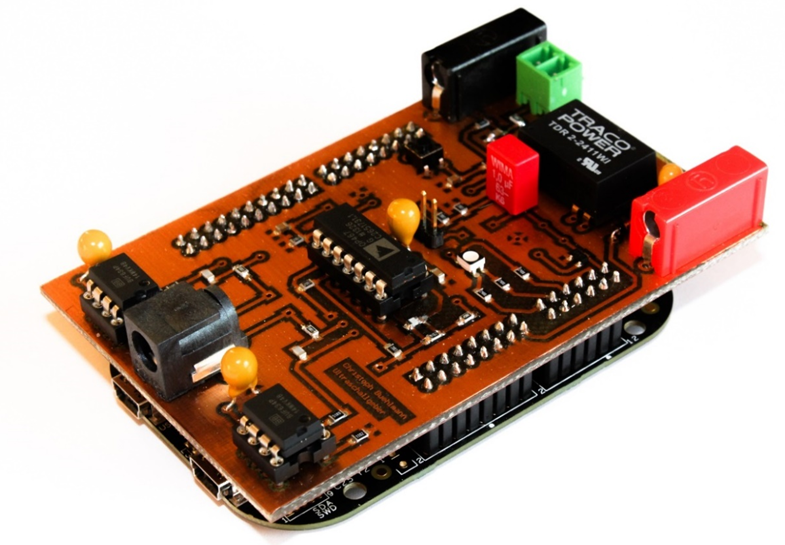
Ultrasonic Shield with FRDM-KL25Z

Ultrasonic Shield with Freescale FRDM-KL25Z (Source: Christoph Bühlmann)

Continue reading →

Tutorial: DIY Kinetis SDK Project with Eclipse – Startup

This is the start of a multi-post tutorial about the Freescale Kinetis SDK, released back in April as beta version. The SDK a set of peripheral drivers, and will become the standard software foundation and drivers provided by Freescale for their ARM Cortex based devices. Similar what other vendors already do. While this is a good step, it is the same time very disruptive for my university projects with new Freescale Cortex-M devices. And with everything new (and beta), it needs time to learn. So this post is about creating a Do-It-Yourself Kinetis SDK project from scratch for Eclipse. This part is about the startup code: about everything to get the application started.

FRDM-K64F with SD, nRF24L01+ and HC-06 Bluetooth

FRDM-K64F with SD, nRF24L01+ and HC-06 Bluetooth

Continue reading →

Combining GPS Data Logger with Google Earth

So I have now a portable GPS data logger (see “Tutorial: Freedom Board with Adafruit Ultimate GPS Data Logger Shield“). What to do with it? It would be cool to see the data and tracks in Google Earth? Yes, that’s doable in a few steps…

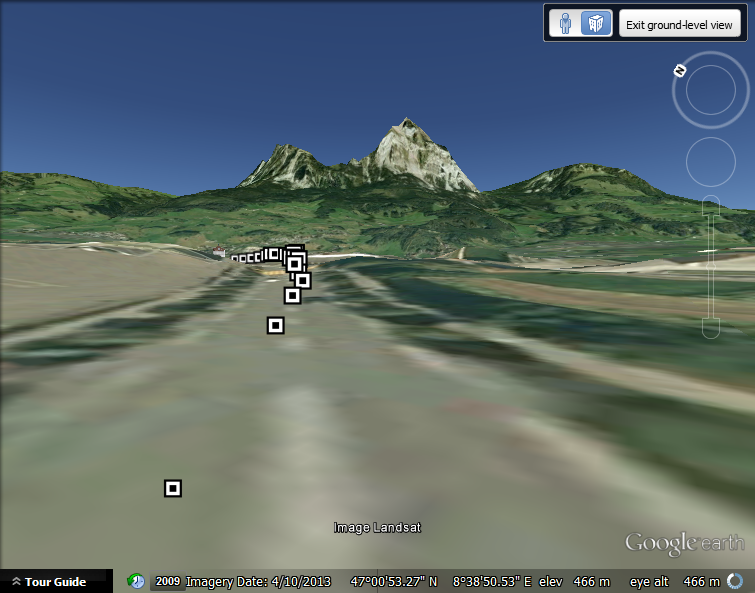
GPS Logger Waypoint Data with Googl Earth Street View

GPS Logger Waypoint Data with Google Earth Street View: Riding through Schwyz towards the Mythen Mountain peaks

Continue reading →

Configuration Data: Using the Internal FLASH instead of an external EEPROM

Many applications need to store persistent (non-volatile) data at runtime: configuration data, error logs, sensor data, calibration values, etc. The question is: where to store that data? If it is only a few kBytes, an SD card or similar is an overkill. Adding an external EEPROM? Sure, that works, but adds an extra part to the design. Some microcontroller have internal EEPROM. But what if not? Why not using the microprocessor internal flash memory?

Internal FLASH vs. external EEPROM

Internal FLASH vs. external EEPROM

Continue reading →